


[ultimate_heading main_heading=”Robots Inter-Press Grippers” heading_tag=”h1″ main_heading_font_family=”font_family:Prompt|font_call:Prompt|variant:300″ main_heading_margin=”margin-top:45px;margin-bottom:10px;” sub_heading_font_family=”font_family:Prompt|font_call:Prompt|variant:200″ main_heading_style=”font-weight:300;” sub_heading_style=”font-weight:200;” sub_heading_margin=”margin-bottom:25px;” sub_heading_font_size=”desktop:24px;” sub_heading_line_height=”desktop:24px;”]Press Line Transfer[/ultimate_heading]
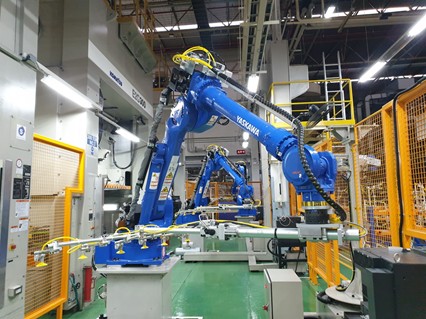
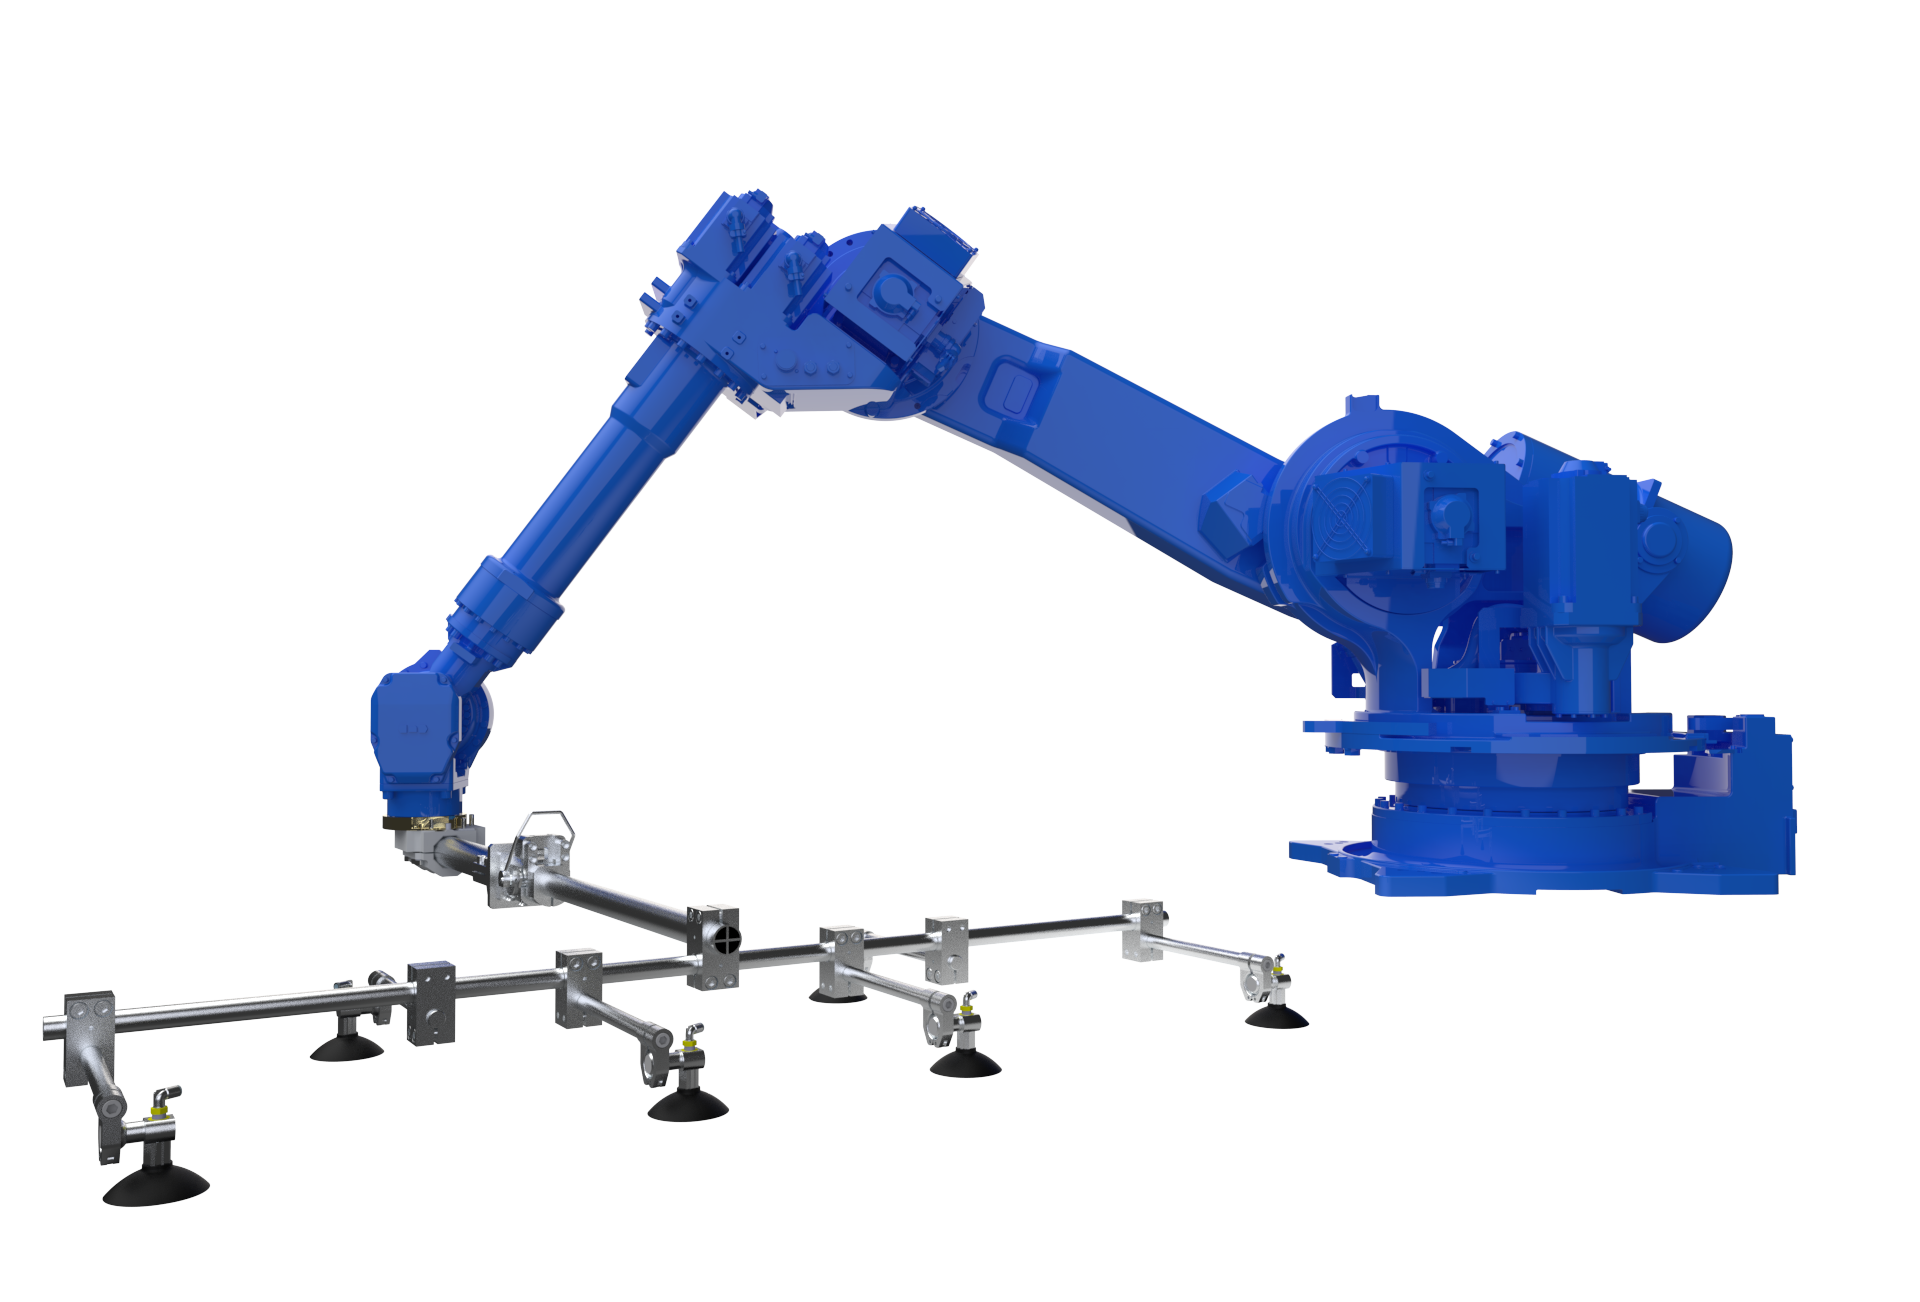
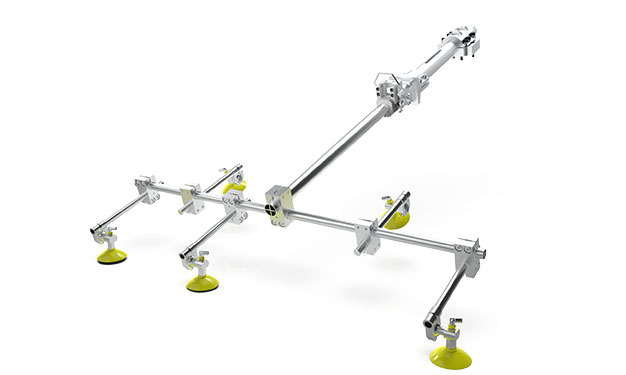
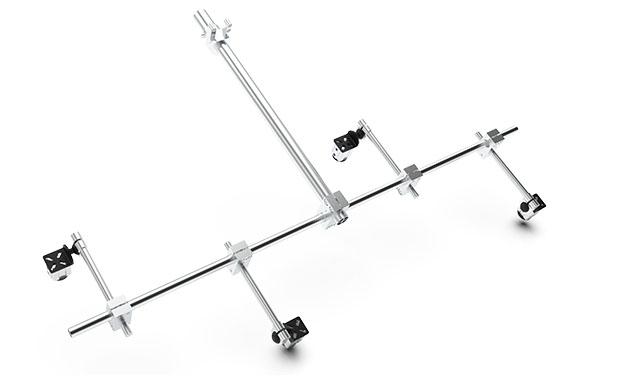
[ultimate_heading alignment=”left” main_heading_font_family=”font_family:Prompt|font_call:Prompt|variant:300″ main_heading_style=”font-weight:300;” sub_heading_font_family=”font_family:Prompt|font_call:Prompt|variant:200″ sub_heading_style=”font-weight:200;” margin_design_tab_text=””]grippers are devices that enable robots to pick up and hold objects. When combined with a collaborative (or cobot’) industrial robot arm, grippers enable manufacturers to automate key processes, such as inspection, assembly, pick & place and machine tending.[/ultimate_heading]